Motor's That Perform
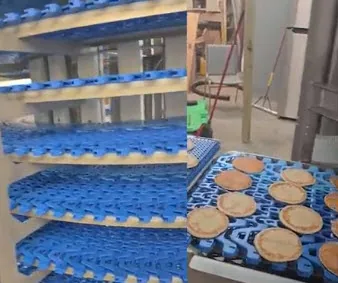
This demo showcases a One Motion Direct Drive Rotary Motion (DDRM) powered pulley directly driving an Intralox 1500 series belt. By integrating the drive teeth into the rotor itself, the system eliminates traditional mechanical components and delivers precise, responsive motion with extremely low energy consumption.
Demo System Overview – DDRM Powered Pulley Driving Intralox 1500 Series Belt
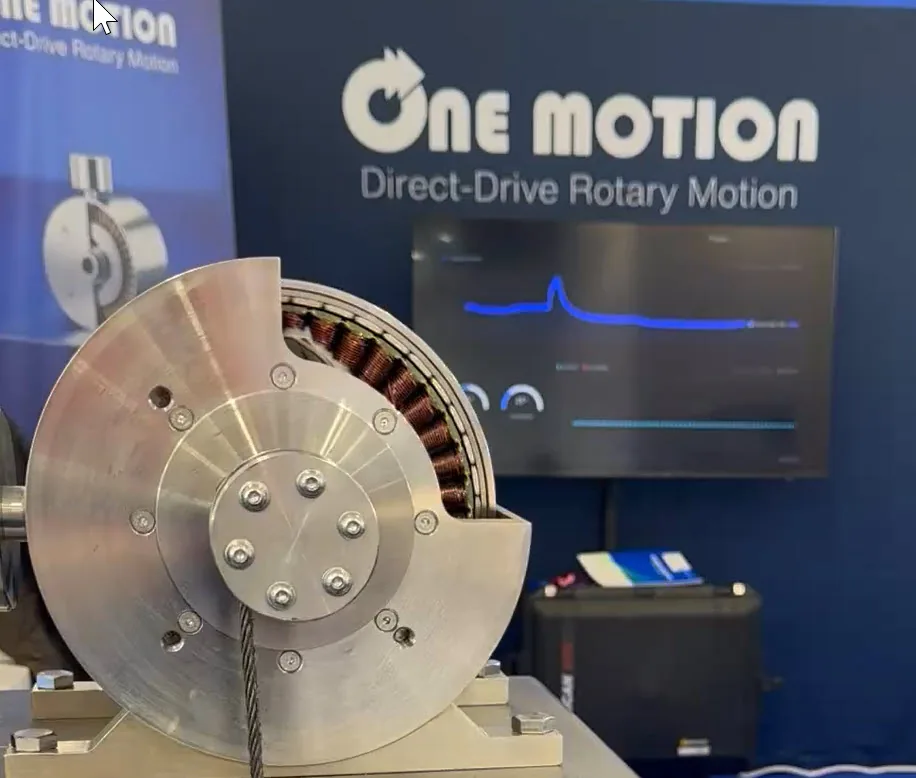
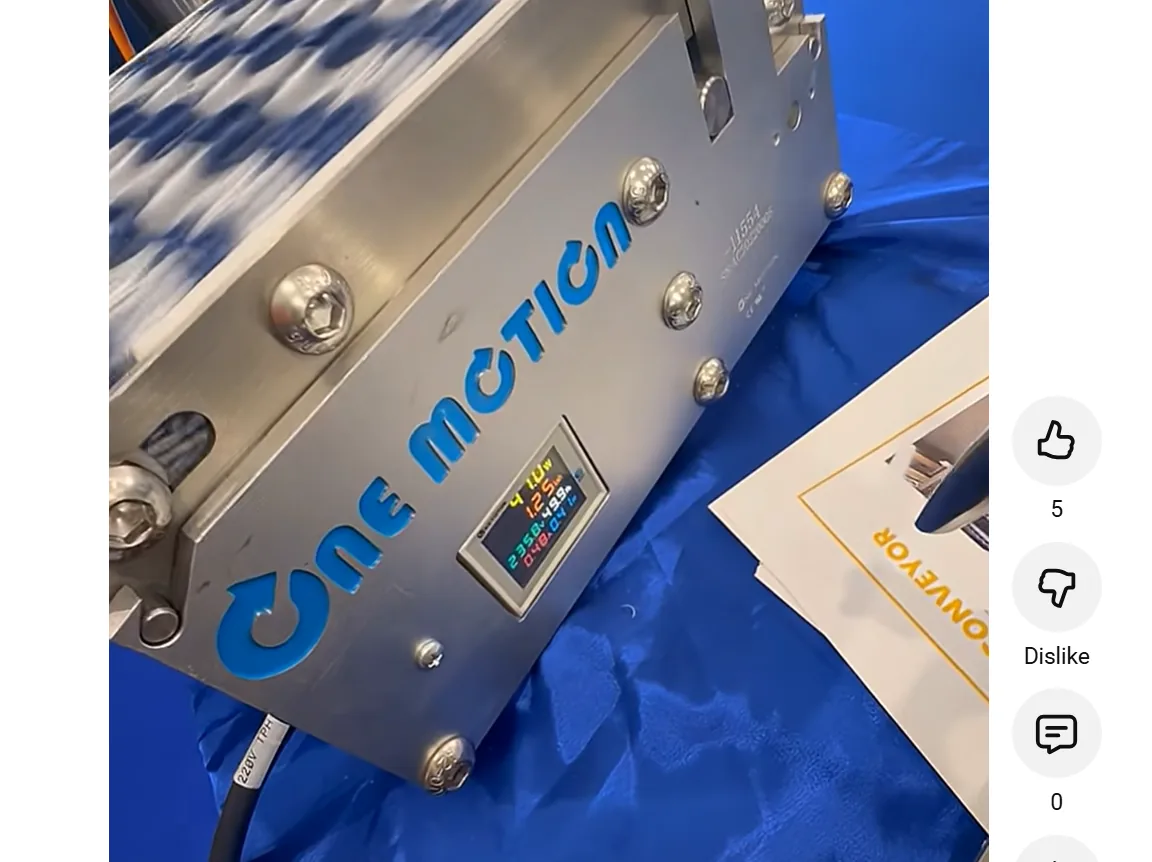
We are running a demo system that drives an Intralox Series 1500 belt using a One Motion Direct Drive Rotary Motion (DDRM) product, OD69-04-58-255-10340.
This configuration uses a cut-shell design, where the drive teeth are machined directly into the outer surface of the rotor. This eliminates the need for a separate sprocket and allows the product to function as a true powered pulley.
Key technical details:
- Peak torque: 4 Nm
- Continuous torque: 1.3 Nm
- Ke value: 0.24 V/rev
- DC bus: 600 VDC
- Maximum achievable speed: ~2,000 RPM
While the motor is capable of operating at high speeds, the belt itself becomes the limiting factor. The Intralox 1500 series is typically limited to about:
- 300 ft/min (1.5 m/s)
With a 17-tooth profile at 0.5 inch pitch, the pitch diameter is approximately 75 mm. This results in a required operating speed of roughly:
- ~400 RPM for typical belt operation
The higher speed capability of the motor is not required for the application, but we intentionally utilize it in the demo to demonstrate the performance envelope of the DDRM platform.
Energy Consumption
One of the most compelling aspects of this system is its efficiency:
- Total demo system: ~50 watts
- Drive electronics: ~10–20 watts
- Powered pulley (DDRM): ~30 watts (depending on load)
This highlights the fundamental efficiency advantage of DDRM systems, where energy is only consumed at the point of work, without the losses associated with gearboxes, chains, or intermediary components.
Dynamic Performance
In the accompanying video, we demonstrate one of the defining characteristics of DDRM:
- Instantaneous directional reversal at full speed
- Zero acceleration and zero deceleration settings
- Multiple rapid direction changes under load
This creates an extremely abrupt transition in rotational direction, clearly showing the responsiveness and control capability of the DDRM system.
There are no mechanical buffers, no backlash, and no compliance in the system. The response is immediate, precise, and repeatable.
Takeaway
This demo is not about achieving maximum belt speed. It is about demonstrating what becomes possible when the drive system is simplified:
- No gearbox
- No sprocket
- No chains or couplings
- No energy lost between components
Just direct, controlled torque applied exactly where it’s needed.
Found this useful? Share it with your team.